3D Reconstruction with Stereo Cameras
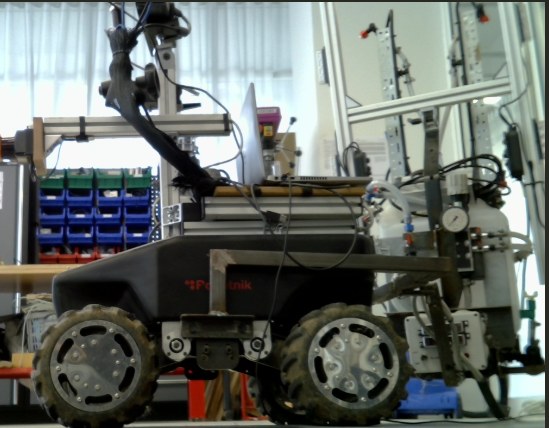
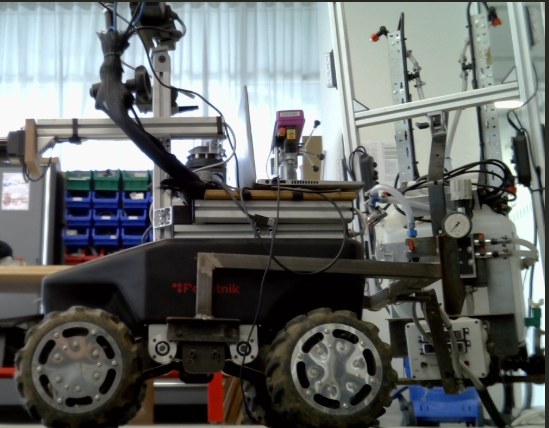
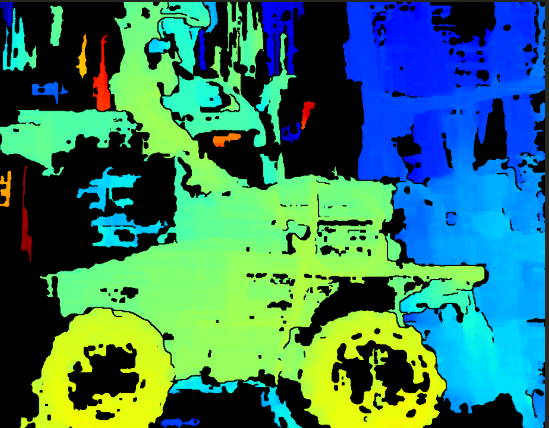
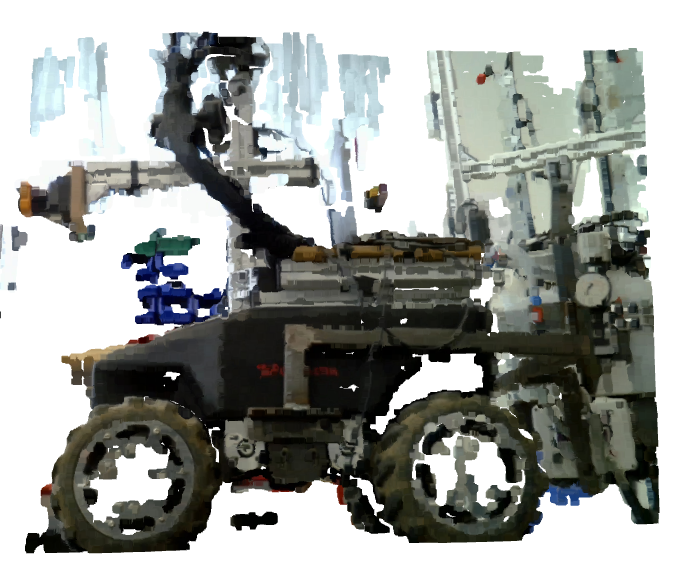
Team course project: a complete stereo vision pipeline that reconstructs a scene in 3D from two stereo cameras, from calibration to a colored point cloud. Beyond the result, the aim was to validate each stage and to analyze its limits critically.
Key points
- Calibration and rectification: chessboard calibration of both cameras (25 image pairs, stereo reprojection error of 0.54 px), then rectification so that matching points lie on the same image row.
- Matching: preprocessing (CLAHE contrast enhancement, bilateral filter), then a disparity map computed with OpenCV StereoSGBM, with optional WLS filtering.
- 3D reconstruction: disparity converted into depth, then into a colored point cloud tested on the Teddy and Coin scenes.
- Critical analysis: comparison with and without rectification, which proved essential for correct matches, and clear influence of calibration quality and of the matching mode on the level of detail.
Technologies: Python · OpenCV · StereoSGBM · Stereo calibration · Point clouds