ROS2 UI — Robot Mission Control Platform
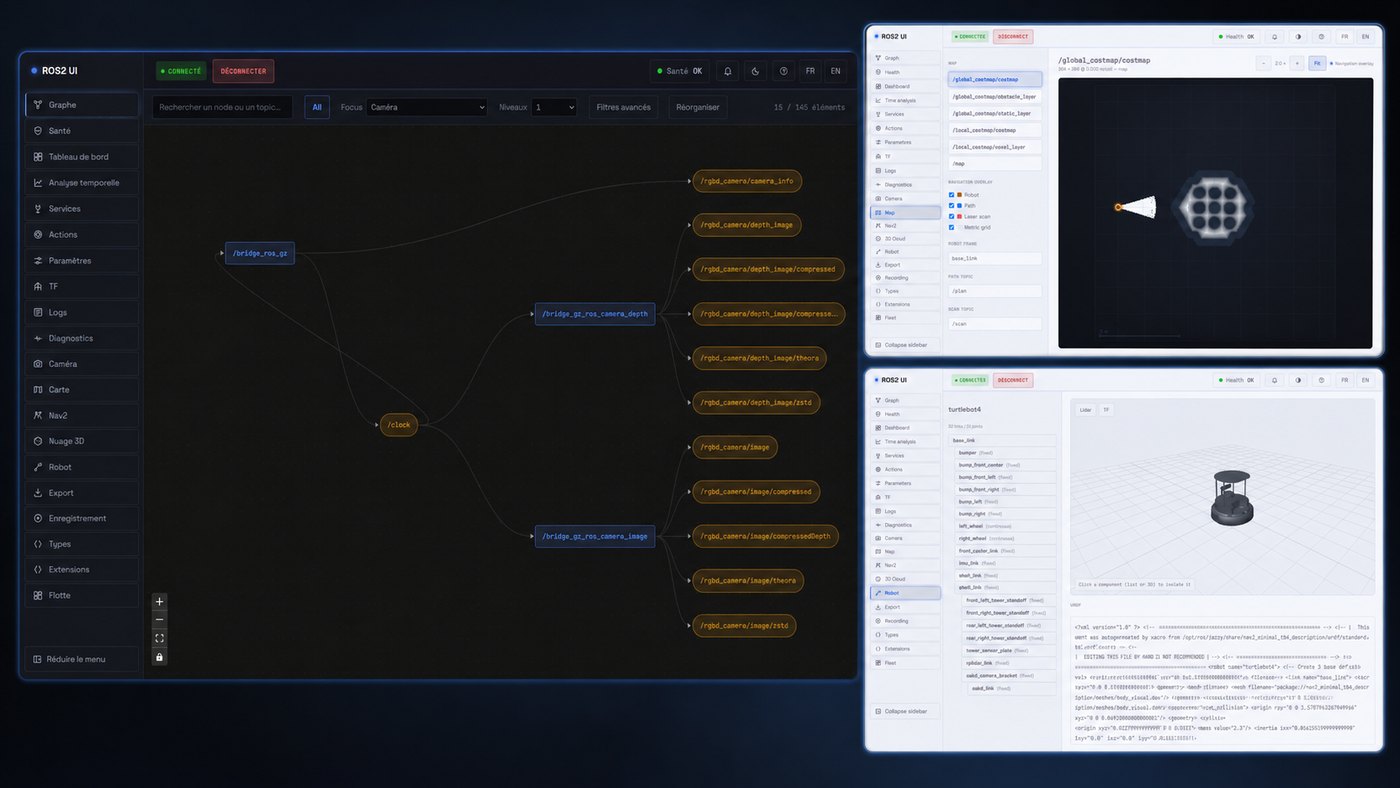
Personal project focused on building a modern, generic web platform for connecting to, visualizing, diagnosing and operating ROS 2 robotic systems in real time.
Main features
- Interactive visualization of the ROS 2 graph, TF tree, topics, services, actions, parameters, logs and diagnostics.
- Live monitoring of cameras, maps, laser scans, point clouds and articulated robot models.
- Navigation tools, alerts, multi-robot fleet supervision, data analysis, export and synchronized rosbag recording and replay.
- Optimized real-time data transport and role-based security for reliable local or remote operation.
Technologies: ROS 2 · Python · FastAPI · WebSockets · React · TypeScript · Three.js · Docker