Heterogeneous Multi-Robot Inspection — Unitree Go2 & G1
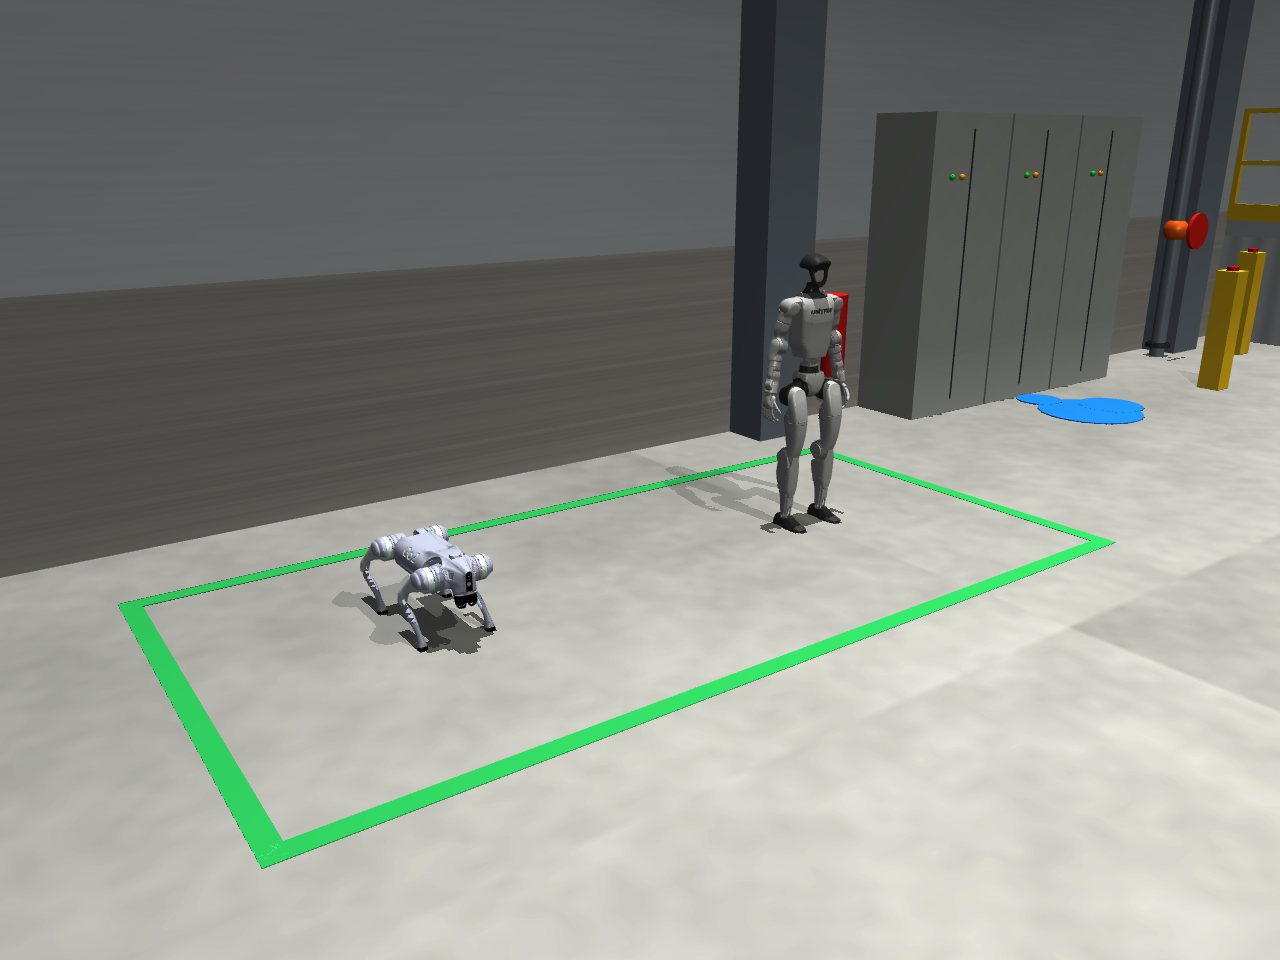
Personal project: a quadruped and a humanoid inspect an industrial site together after an incident, in MuJoCo simulation. The Go2 explores, maps and spots anomalies; the G1 then reaches them and presses an emergency stop button; a coordinator allocates the tasks according to what each robot can reach.
Done
- Go2 locomotion learned by reinforcement (PPO), trained on GPU with 4,096 robots in parallel: it climbs and descends 11 and 14 cm stairs facing the steps, with no falls over 100 episodes.
- G1 walking on flat ground: forward, backward, sidestep and turning on command, with no falls over 100 episodes and commands tracked within 0.05 m/s and 0.02 rad/s.
- A 20 × 15 m industrial site generated from a seed: a staircase and platform only the Go2 can reach, a ramp, a debris area and anomalies.
In progress
- Making the G1’s walk robust: pushes, domain randomization and slopes.
Next steps
- Go2 autonomy: simulated 2D lidar, occupancy grid, frontier exploration and anomaly detection.
- G1 intervention: path to the anomaly, arm inverse kinematics and pressing the stop button.
- Full mission with both robots, with auction-based task allocation compared to a greedy one.
Technologies: MuJoCo · MuJoCo Warp · PyTorch · rsl_rl · Stable-Baselines3 · Gymnasium · Python